The Robot's Hand Matters as Much as Its Brain
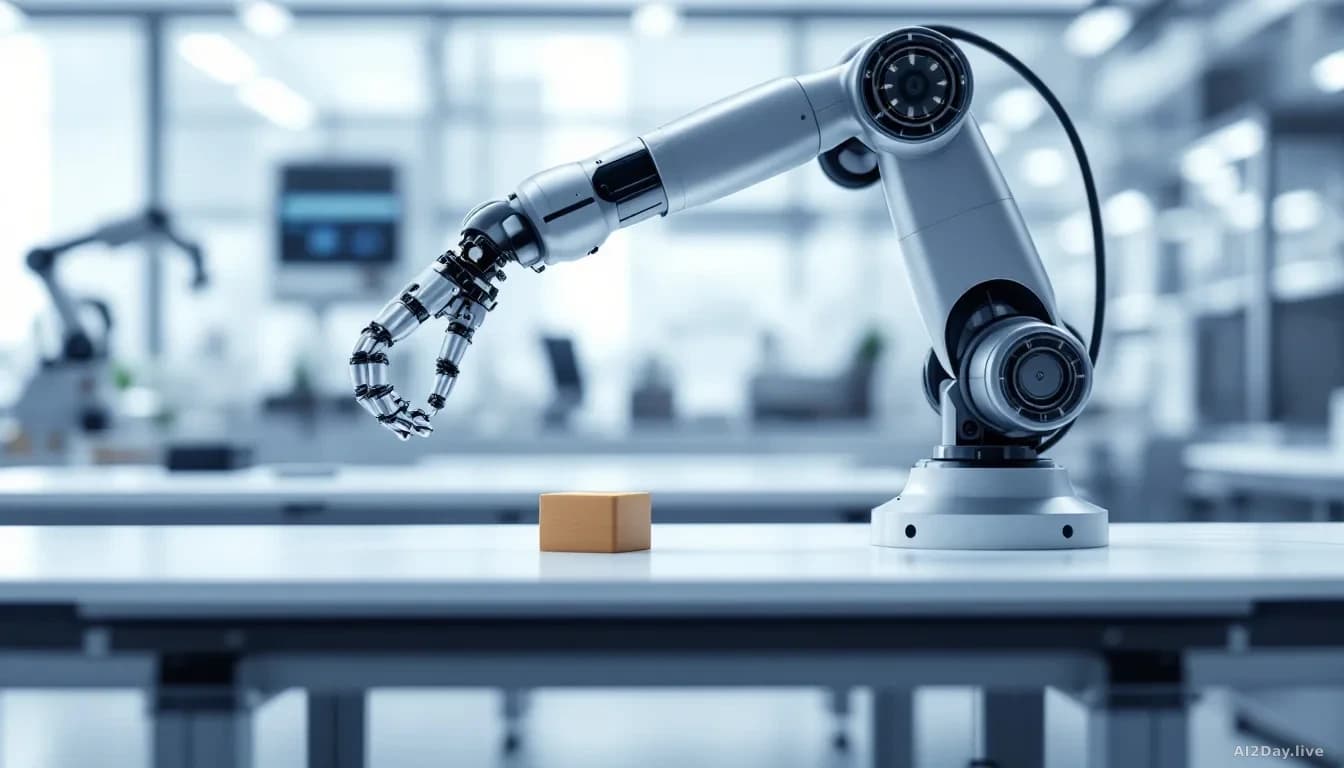
AI can tell a robot exactly what to do. But if the gripper can't feel what it's touching, the smartest model in the world still drops the box.
Key points
- Physical AI, software that lets robots perceive and act in unstructured environments, depends on hardware at least as much as on the AI model itself.
- End-of-arm tooling (the grippers and sensor attachments at the tip of a robot arm) is now considered a core part of intelligent robot systems, not an afterthought.
- Force and proximity sensors in grippers give AI models real feedback that cameras and computer simulations can't fully replicate.
- Gripper portfolios covering two-finger, three-finger, vacuum and magnetic tools with quick-swap connectors expand what a robot can realistically do.
- OnRobot's RG2-FT gripper, which combines gripping with built-in force and proximity sensing, is one example of hardware designed to close this gap.
Robots are getting smarter. AI models trained on enormous datasets can now tell a robot arm how to pick up an unfamiliar object, adjust for a crooked part, or hand something delicate to a human colleague. The intelligence is real, but the hand keeps letting it down.
That's the argument Thomas Houden, Director of Global Business Development at OnRobot, put to The Robot Report: the gripper at the end of a robot arm isn't a dumb attachment anymore. It's a critical piece of the AI system itself. Our 26 August story on the limits of physical AI made much the same point from the software side; Houden makes it from the factory floor up.
Why can't the AI just figure it out?
It can plan beautifully. Carrying that plan into the physical world is the hard part.
An AI model can decide that an object needs picking up. A physical gripper still has to make contact, press with exactly the right force, check whether the grip held, and react if something slips. Every single time, in conditions that shift constantly. A part that's slightly wet, a component 2 mm out of position, a surface smoother than expected: simulation and cameras miss these things. Sensors in the gripper don't.
Force and torque sensors measure the push and pull at the point of contact. Proximity sensors fire before the gripper even touches the object. Together they give the AI a live feed of what's actually happening, rather than what the model assumed would happen.
OnRobot's RG2-FT gripper packages all of this into one unit. Fingertip sensors detect slip and asymmetric contact the moment they occur, feeding that information back to the AI so it can correct in real time.
What does this mean for real factories?
A brilliant AI model paired with a basic gripper is limited to simple, predictable tasks.
Real manufacturing environments are full of variation. Parts arrive at slightly different angles; materials differ between batches. A gripper with adjustable force settings and live feedback can handle that variation. A rigid gripper without sensing can't, no matter how capable the AI driving it is.
Different jobs need different tools:
| Tool type | Best use |
|---|---|
| 2-finger gripper | Wide range of general handling tasks |
| 3-finger gripper | Cylindrical parts that need auto-centering |
| Vacuum tool | Flat or smooth surfaces |
| Magnetic tool | Metal components |
| Force/torque sensor | Delicate or contact-heavy tasks |
| Tool changer | Swapping between any of the above automatically |
A robot that can swap tools mid-task, guided by a flexible AI policy, is far more useful on a factory floor than one locked to a single attachment. That's the practical upshot for anyone specifying automation right now: budget for the gripper portfolio, not just the model license.
Common questions
Does better hardware replace better AI, or do you need both?
You need both. The AI decides what to do; the hardware carries it out and reports back. Improving one without the other hits a ceiling quickly.
Is this relevant outside manufacturing?
Yes. The same principles apply anywhere a robot touches the physical world: warehouses, surgery and food handling all face the same sensing gap between a camera's view and what's actually happening at the point of contact.